- Dimensions (H × W × L)
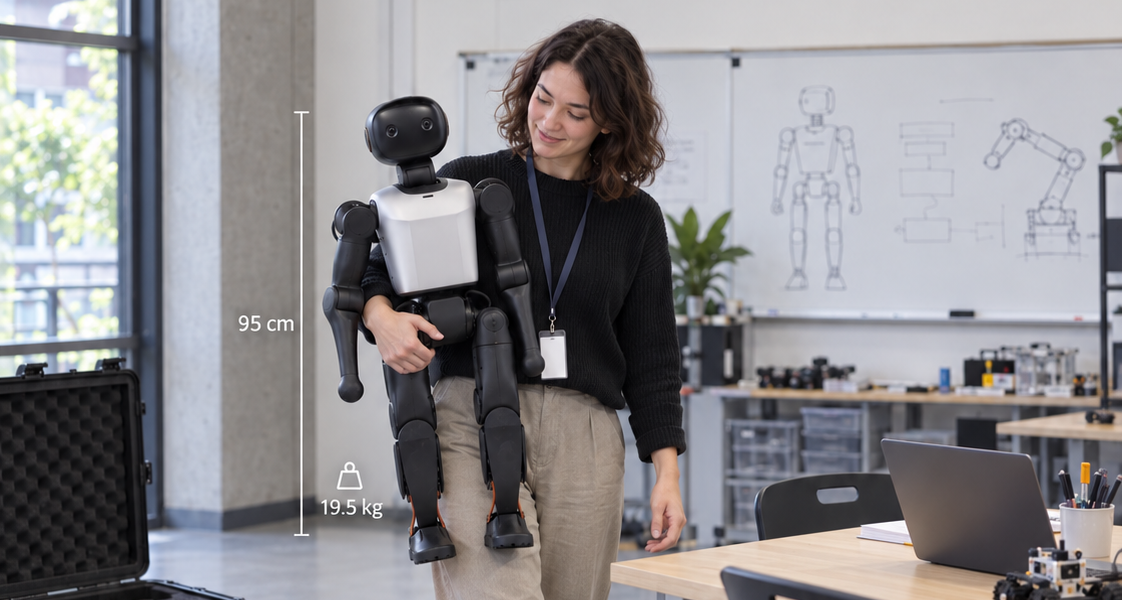
- 950 (H) × 400 (W) × 180 (L) mm
- Weight
- ≈19.5 kg
- Materials
- Aluminum alloy, high-strength engineering plastics
- Degrees of Freedom (DOF)
- 22 DOF
- Maximum Movement Speed
- Max 1.1 m/s; turning 1.5 rad/s
- Peak Joint Torque
- 60 N·m
- Battery Capacity
- 5 Ah
- Power Supply Method
- Direct charging, replaceable battery
- Runtime / Battery Life
- 80 min @ 0.4 m/s
- Charging Time
- ≤ 2 h
- Telecommunication
- Wi-Fi 6, Bluetooth 5.2, Gigabit Ethernet
- Mobile App
- Supported
- Cameras
- Stereo depth camera, head-mounted
- Other Sensors
- Ring 3-mic array + speaker; dual joint encoders with torque feedback
- IMU
- 9-axis IMU
- Operating System
- Linux; ROS 2 supported
- High Performance Computer Board
- NVIDIA Jetson AGX Orin 32GB, 200 TOPS
- OTA Update Capability
- Supported
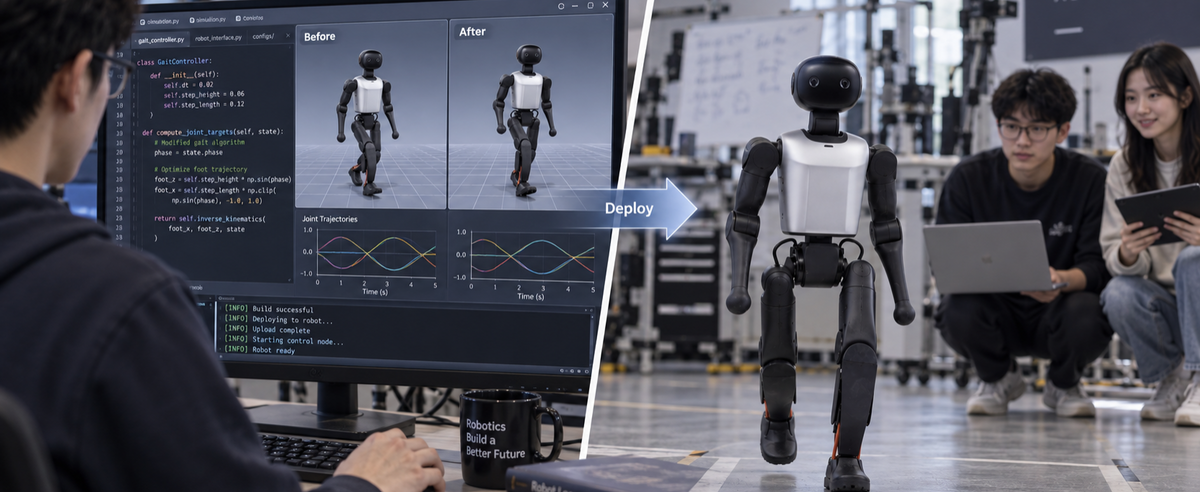
- Secondary Development
- Supported — SDK / ROS 2 SDK, Python & C++
- USB Ports
- USB-C
- LAN Ports
- RJ45 × 1, Gigabit Ethernet
- Includes
- 1× humanoid robot device
- Controller
- 1× remote controller
- Charger & Battery
- 1× charger, 5 Ah battery
- Transport Case
- 1× transport case
- Computing
- Upgrade to Jetson AGX Orin 32GB
- OTA Update
- Supported